MimicX: Policy-in-the-Loop Supervision Refinement for Video-Driven Humanoid Motion Tracking
, Chenglong Zhang, Xuhao Liu, Feiyang You, Yifan Liao, Shuyang Hao, Chaozhe Zhang, Chengyu Wu, Zhen Sun, Ningxin Su#
arXiv preprint 2026
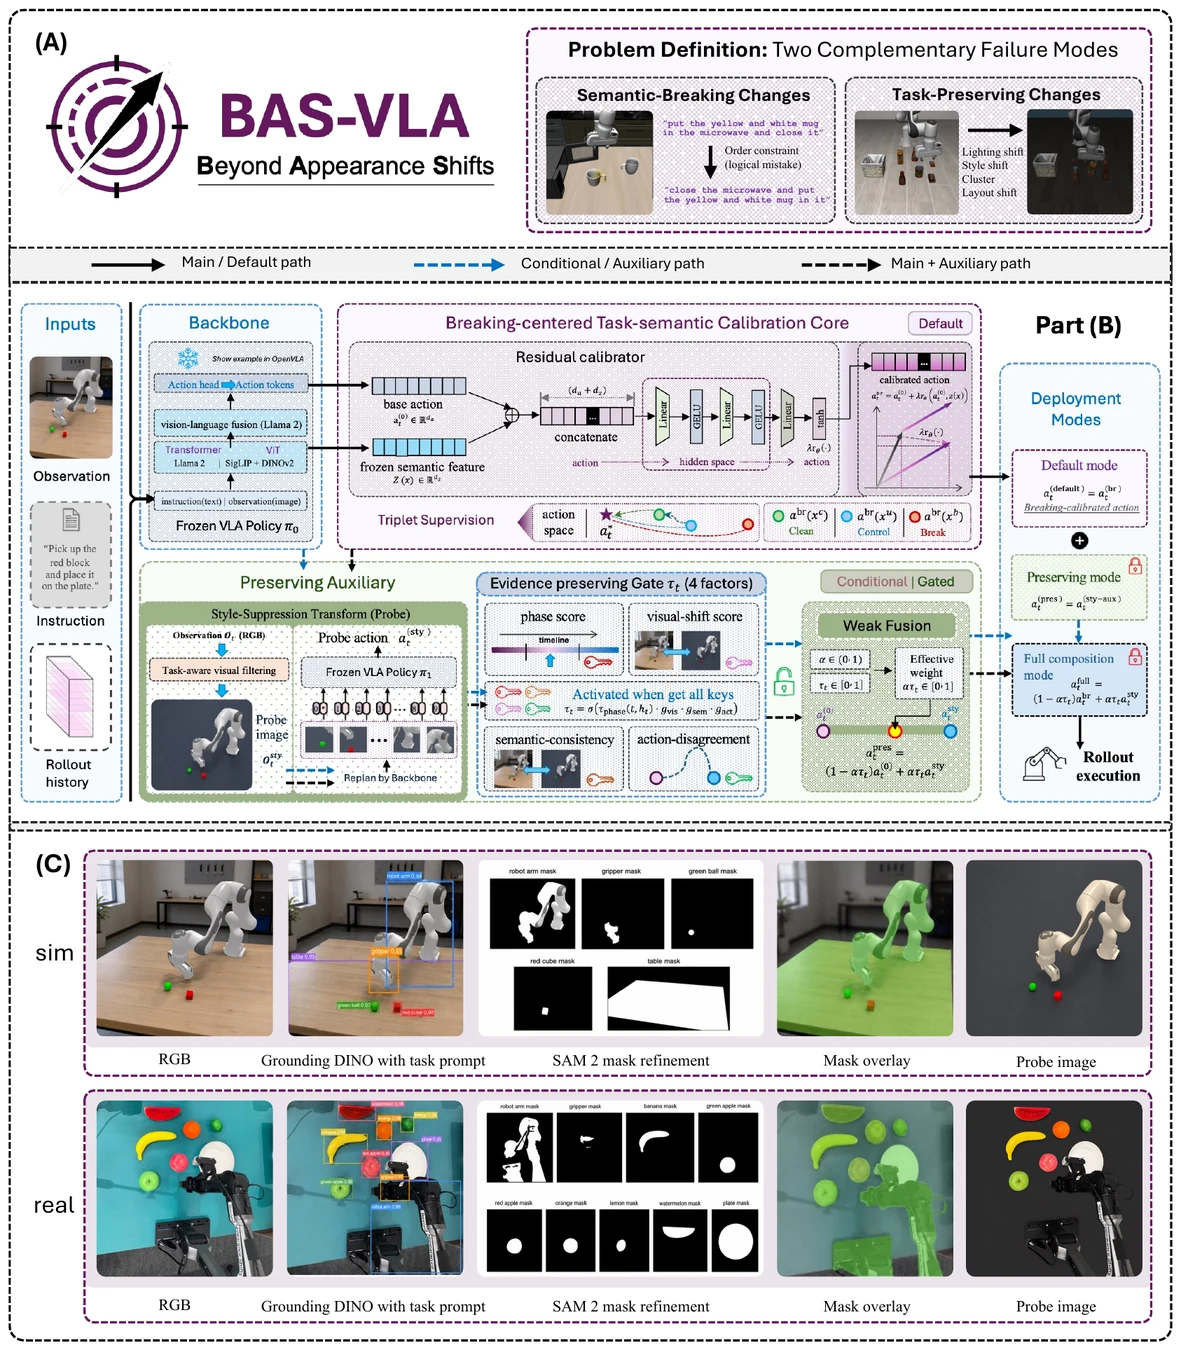
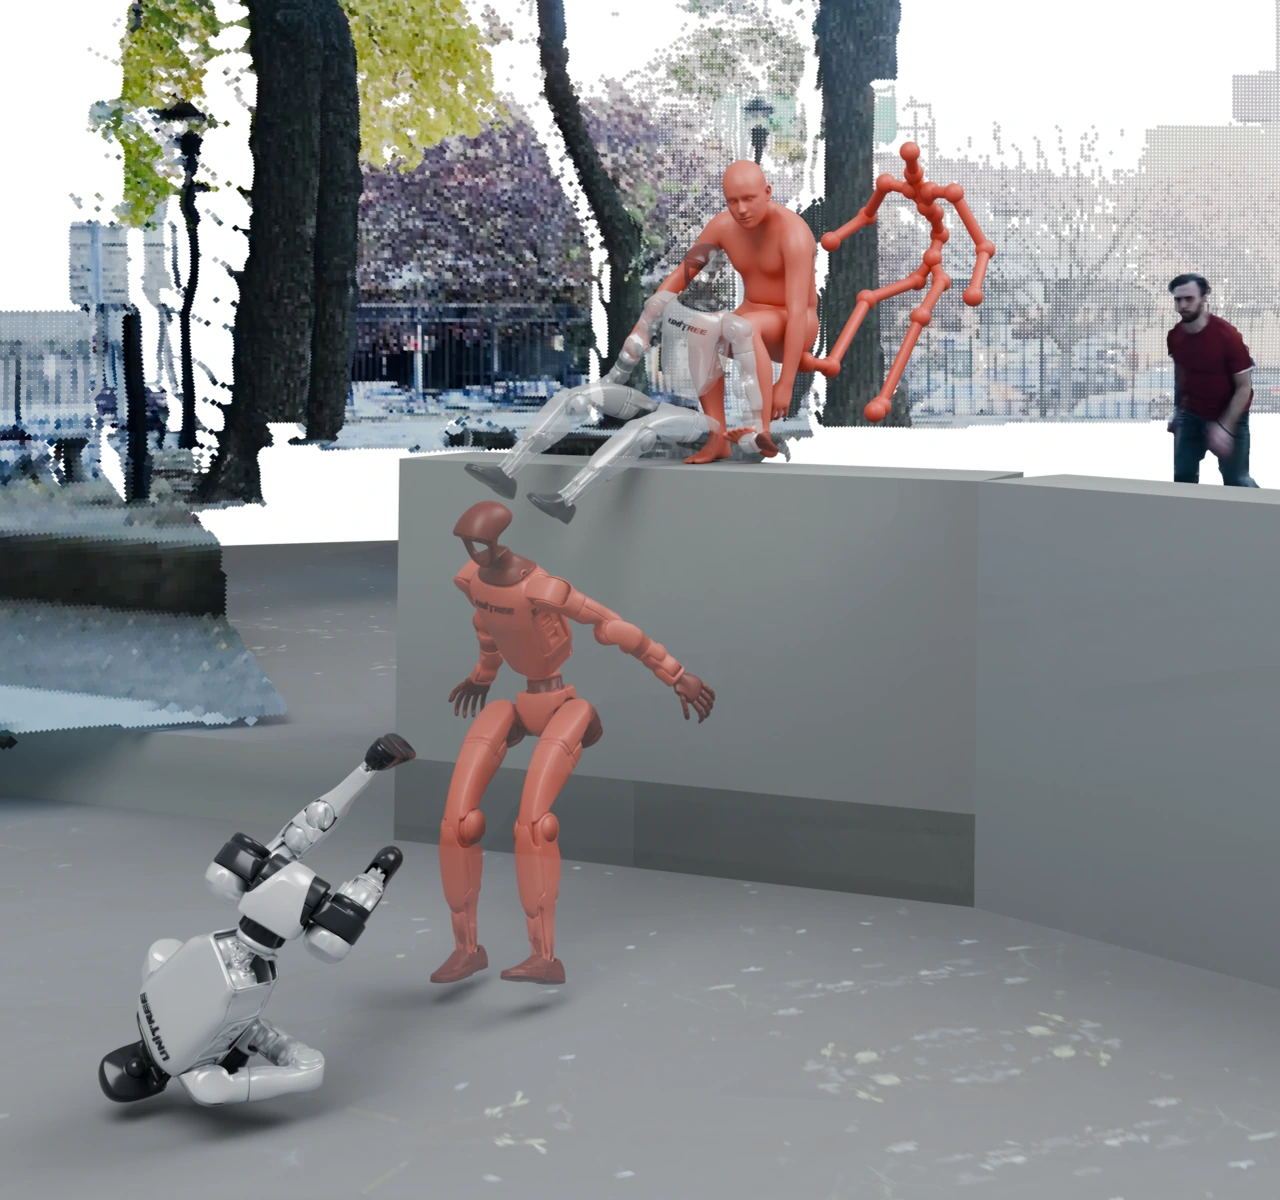
Uses policy execution feedback to refine supervision for video-driven humanoid motion tracking. MimicX identifies difficult transitions and affected body regions, adapts tracking objectives and reset curricula, and verifies refinements through repeated rollouts. Across four core video tasks, it reduces body-tracking error by 25.7% and increases robust execution horizon by 255.6% over fixed-reference training.